Making a hand that’s capable, reliable, and manufacturable is a very hard problem
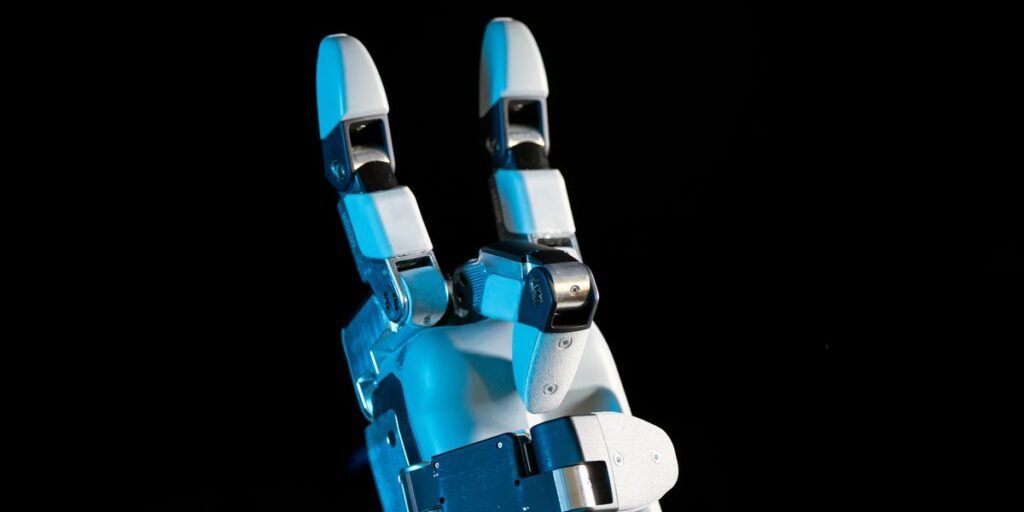
Three fingers and a thumb with 13 degrees of freedom is what Boston Dynamics says its hand needs—to do just about everything.
Today,Boston Dynamicsisannouncinga redesigned hand for itsAtlas robot. The previous generation could do somecrazy superhumanthings with its three fingers, but it was never intended for mass production in the tens or hundreds of thousands. Switching from research hardware to a scalable product makes previously ignorable questions suddenly paramount: How can you make a hand that does everything you need it to do but is also rugged and reliable and …
Compared to the almosteerily humanlike handsdesigned by a litany of otherhumanoidroboticscompanies, Atlas’s new hand does look awfully clunky. We’ve certainly seen some of those robots with much more humanlike hands perform dexterous manipulation tasks that are, speaking as someone who has personally witnessed robots haplessly fumble their way through the world for nearly two decades now, nothing short of incredible. And it’s not just what these …
“Hands are a ruthless design trade-off,”Alberto Rodriguez, director of robot behavior atBoston Dynamics, tellsIEEE Spectrum. “There’s no way around it, you’re always giving up on something. And many of the current designs are giving up on things like reliability and manufacturability.” This is what invariably happens when you try and cram everything necessary to make a robotic hand function within the form factor of a human hand: It’s going to be…
With Atlas’s new hand, Boston Dynamics is making the design trade-offs necessary to achieve a hand that, according to the press release, is capable of a vast array of useful tasks, including using tools; is strong and rugged; can be cleanly simulated; can be mass-manufactured and repaired at reliably low cost; and is close enough in form factor to a human hand that human demonstrations can be used to train it.
You’ll notice that “looks cosmetically like a human hand” is nowhere on that list, and this new hand doesn’t. Rodriguez explains that getting rid of the pinky was a straightforward decision, agreed on after his team spent a day with their pinkies taped to their ring fingers. But why even add a fourth finger, when the previous generation of Atlas’ hand seemed to do well with only three? It’s not just the extra finger, but a complete redesign that …
“We also added the ability for the fingers to splay open because we knew that it was important for one finger to be able to move against another, and we also knew that we needed to be able to hold the handle of a tool with a trigger,” Rodriguez says, which includes many common tools like drills or welding torches. “We’re convinced that from a product perspective, this hand should be able to do everything we need it to do for the foreseeable horiz…
Reliability, manufacturability, and cost are all closely related. By reducing the degrees of freedom relative to other more anthropomorphic hand designs down to just 13, Boston Dynamics can use fewer, larger, and more powerfulactuators. The actuators are embedded directly into the joints themselves in a direct-drive configuration, with a transmission that allows the motors to be back-driven and react to force and contact. Each actuator pack is a …
Not every humanoid company will make the trade-offs that Boston Dynamics has done here, and there’s still plenty of room for creativity when it comes to hand design. But if humanoids with hands are going to scale, some difficult decisions will have to be made, and it’ll take some compromise to deliver on the promises that the humanoid industry has committed to.
Evan Ackermanis a senior editor atIEEE Spectrum. Since 2007, he has written over 6,000 articles on robotics and technology. He has a degree in Martian geology and is excellent at playing bagpipes.